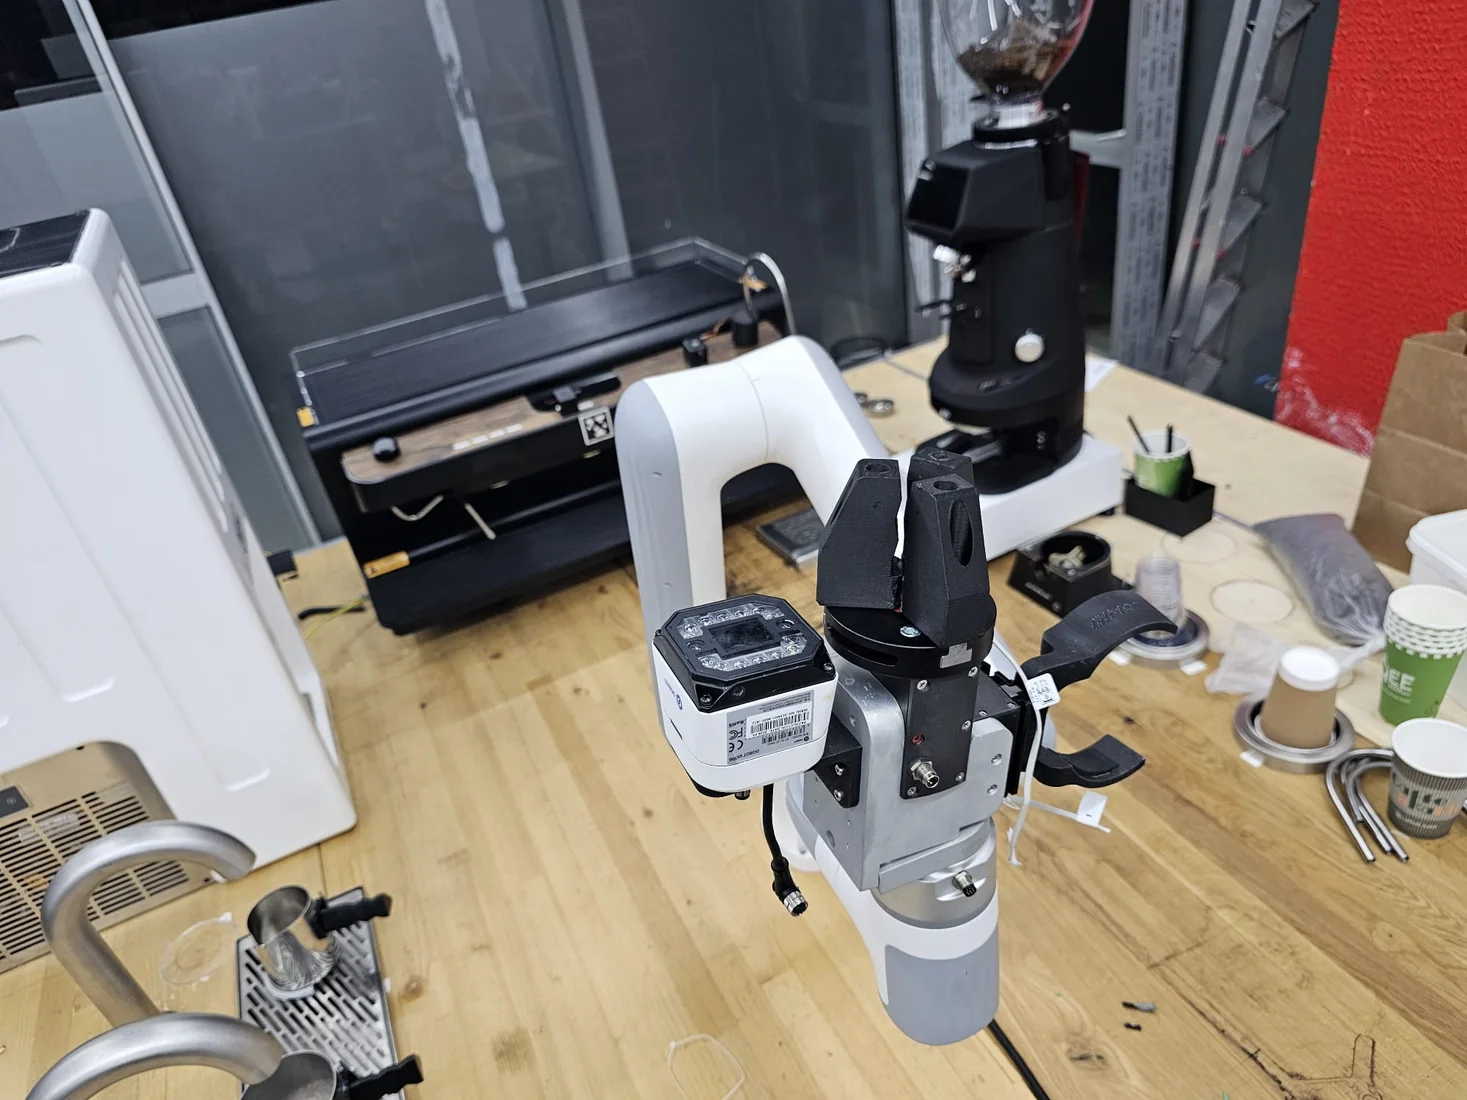
Tool handling
Cup, pitcher and equipment positions are considered together with the robot’s reach and gripper.
Hayzek’s robotic barista project, bringing coffee equipment and robotic manipulation into a shared workflow.
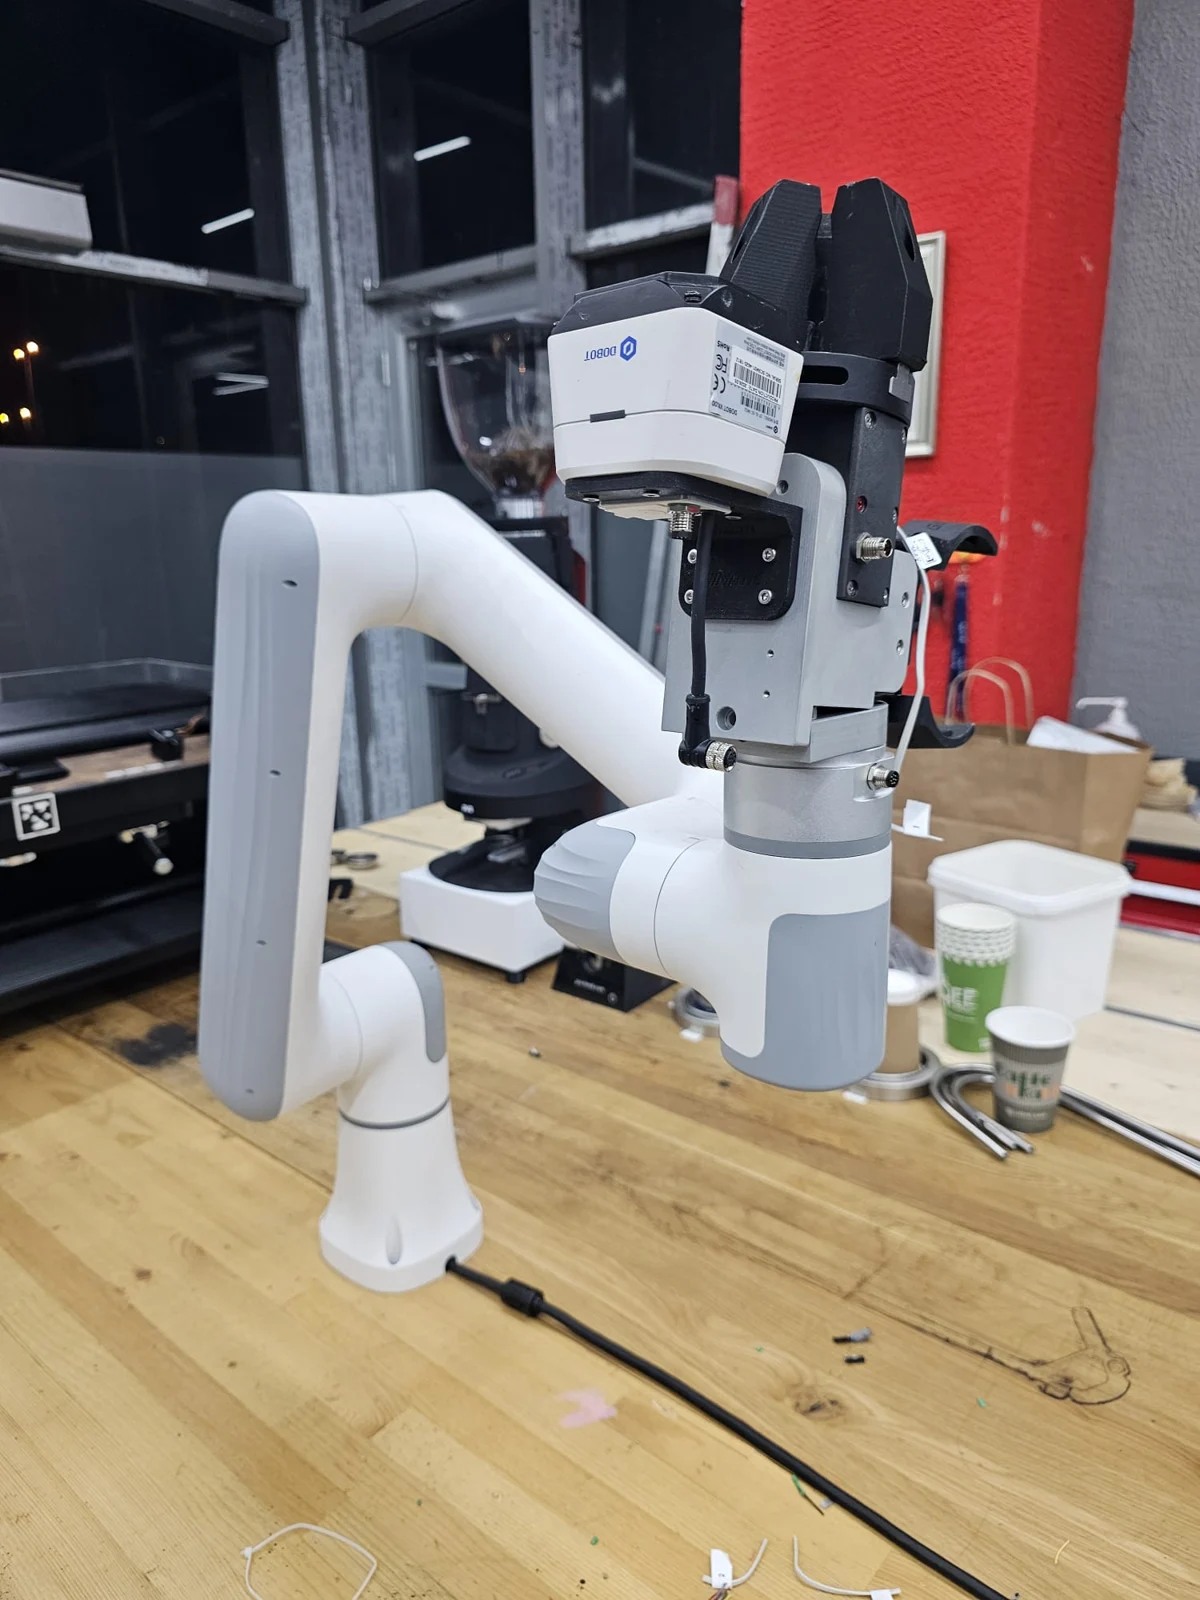
Cup, pitcher and equipment positions are considered together with the robot’s reach and gripper.
The espresso machine and surrounding equipment form part of the coordinated preparation workflow.
Pitcher handling and controlled pouring are application development areas.
Preparation, transfer and presentation steps are evaluated as a complete task sequence.
A service automation application intended to integrate a robot arm with ordering, beverage preparation, dispensing, delivery and cleaning. Development and pilot work focus on coordinated equipment management and consistent service.
Make service workflows traceable, use capacity more effectively at peak times and support consistent product quality.