Industrial facility inspection
Assess assets, measurement points, task routes and sensor requirements together.
BAYBARS is our hybrid platform approach combining wheeled-legged mobility with task-specific sensors, software and equipment integration. Project scope is developed for facility inspection, remote observation and applications involving varied terrain.
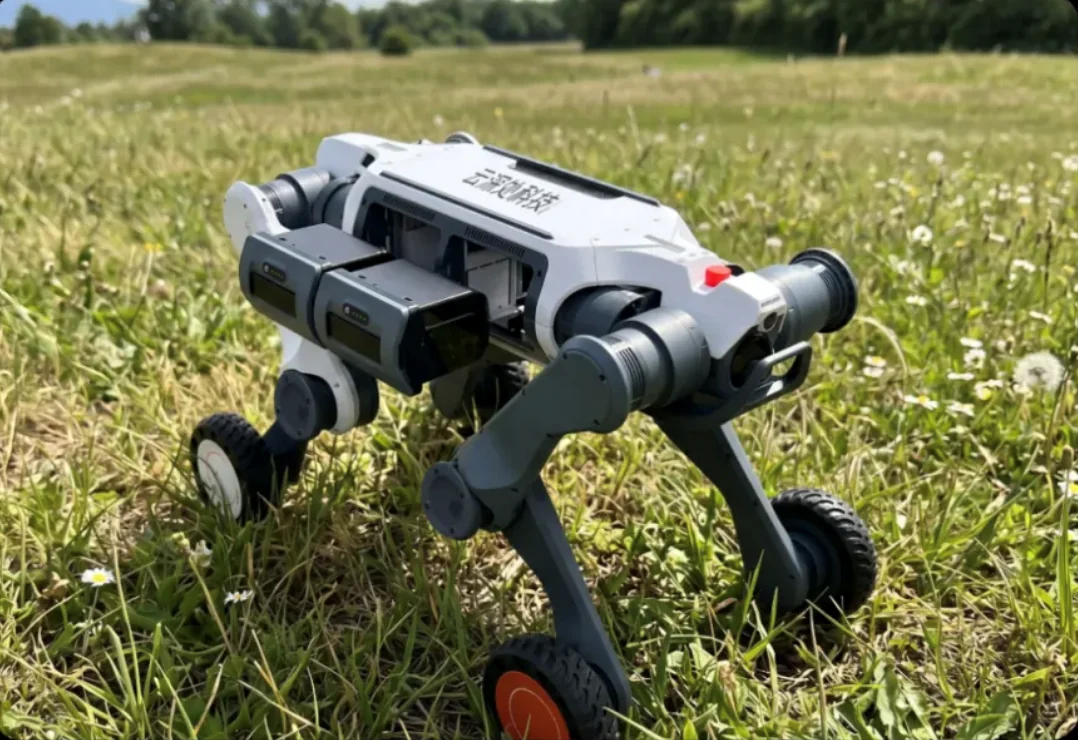
Technical overview of the reference configuration.
Assess assets, measurement points, task routes and sensor requirements together.
Review environmental conditions and communications for substations, facility routes and field observation.
Define imaging, operator interfaces and task data transfer around project requirements.
Assess mechanical, electrical and software compatibility for cameras, measurement devices and other task components.
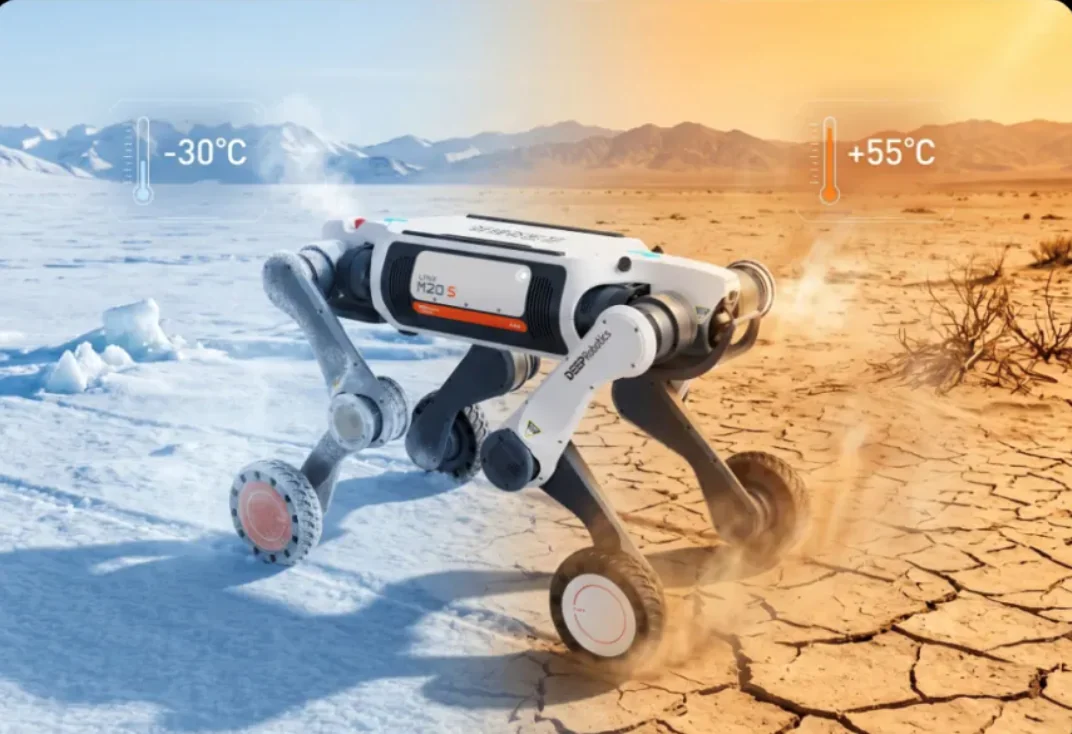
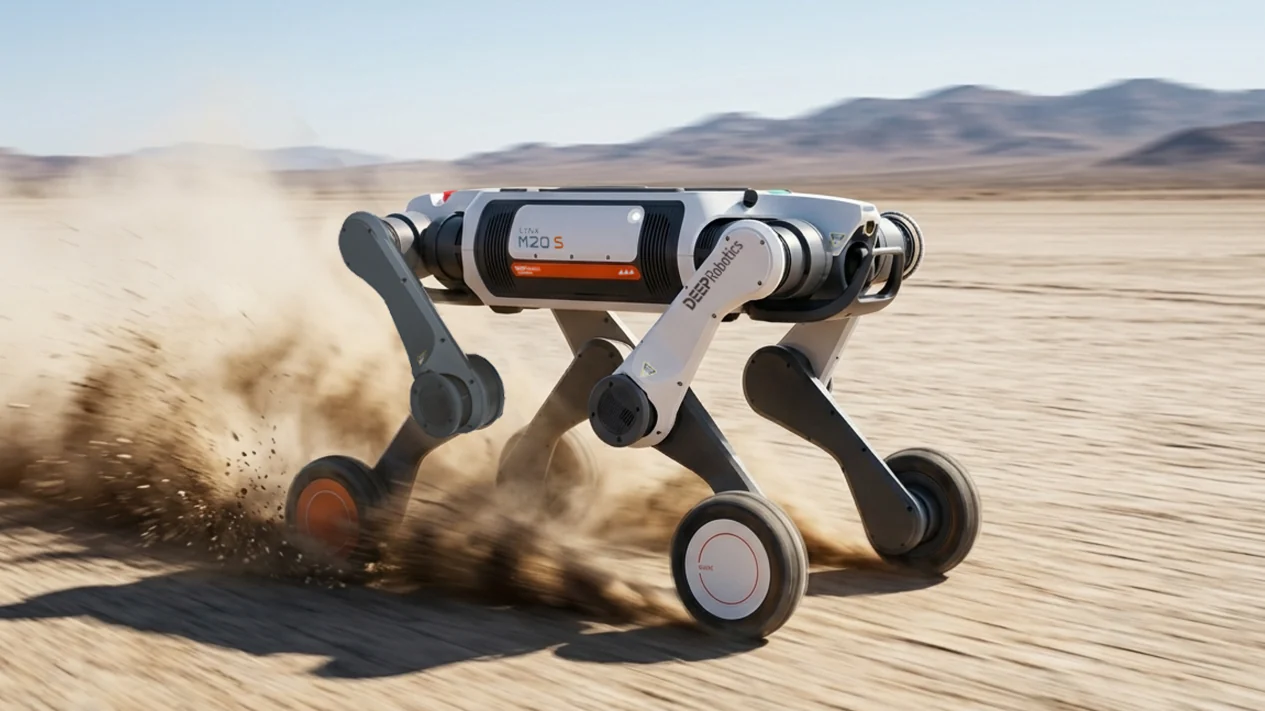
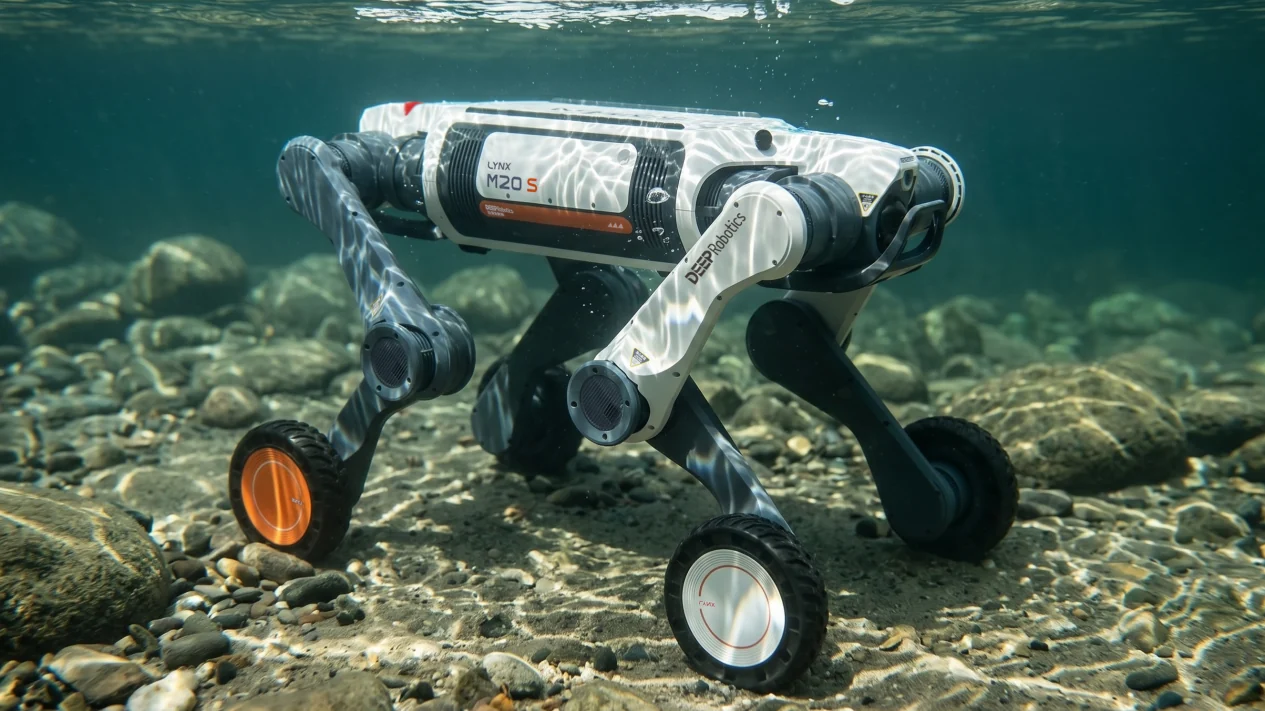
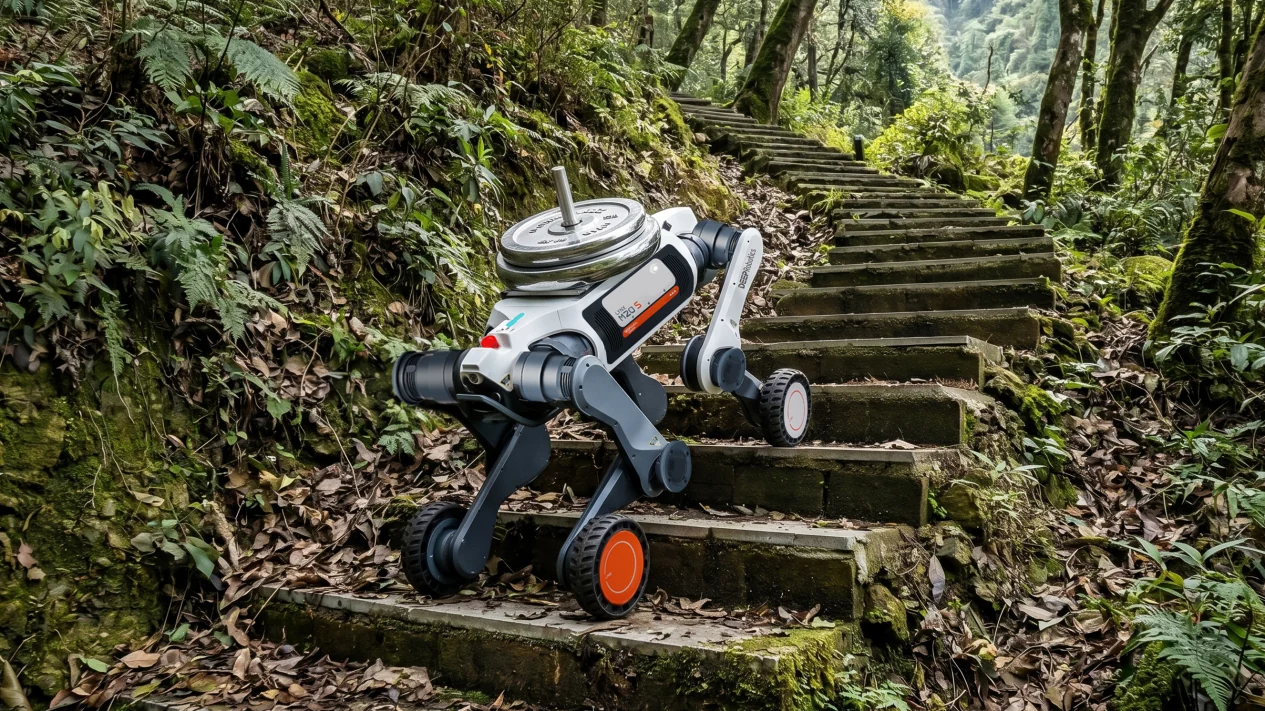
We address requirements analysis, carrier selection, task equipment and sensor integration, task software, simulation and field validation together. Final system specifications depend on selected hardware, site conditions and acceptance criteria.