Mobile inspection and task integration

AYBARS-E

Field data. Operational visibility.

AYBARS-E is an application system combining robotic mobility, sensors and task software for industrial inspection, patrol and data collection. Routes, task equipment and reporting scope are configured around facility conditions.

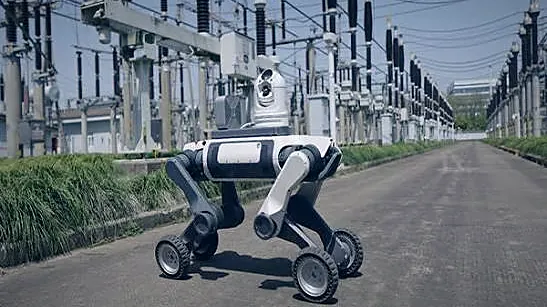
Reference platform for mobile inspection in an energy facility.

The images illustrate application references on different robot platforms. The AYBARS-E carrier and equipment configuration are selected within the project scope.

Which needs does it address?

Scheduled facility inspection

Define checkpoints and task routes to observe equipment and record images and sensor data.
Energy and infrastructure observation

Monitor selected equipment in substations and facility grounds. Cameras and measurement modules are selected around inspection needs.

Initial observation in hazardous environments

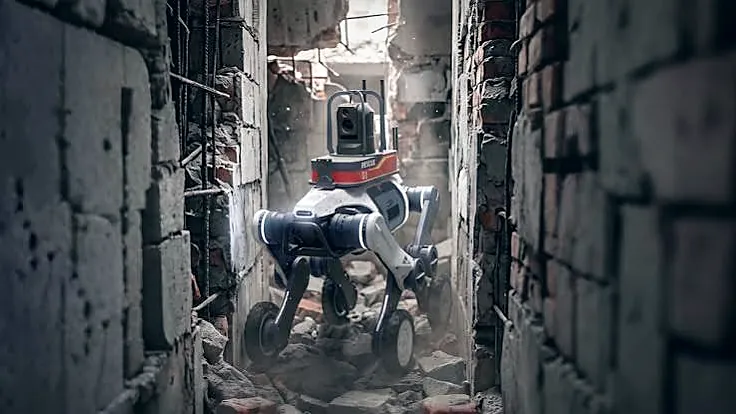
Remote imaging scenarios in damaged or difficult-to-access areas. Site suitability, communications and operator control are assessed together.

On-site task support

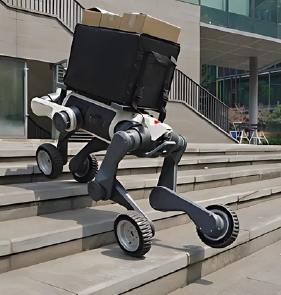
Additional applications such as carrying small equipment between locations. Payload, access routes and movement conditions are validated for the selected carrier.
Task equipment and data scope

Imaging
Camera selection for visual inspection and remote observation.
Measurement
Assessment of thermal or environmental sensors according to the task.
Navigation
Routes, checkpoints and indoor positioning requirements.
Data transfer
Transfer of task records and sensor outputs to the relevant operations system.
Task equipment
Mechanical, electrical and software compatibility for carrying or using specialised equipment.

Application references

Reference visual illustrating remote observation inside a damaged structure.
Wheeled-legged reference platform carrying a load on a stepped route.
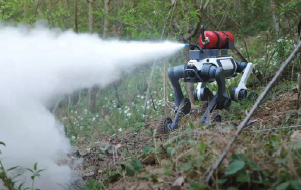
A robotic platform carrying spraying equipment: a reference for specialised task integration.

The carrying and spraying images illustrate additional tasks that can be assessed; they are not a standard AYBARS-E equipment package.

From requirements to field validation

1. Define the site and task

Identify routes, surfaces, stairs, checkpoints, access conditions and required data.

2. Configure and integrate

Assess the carrier, sensors, communications, task software and operator interface together.

3. Pilot and acceptance

Test task completion, data quality, operator intervention and site suitability against agreed criteria.

Let’s define the project scope together.

Operating time, payload, environmental resilience and autonomy depend on the selected platform and equipment. Maintenance, remote support and software updates are planned within the service scope.